


South Korea’s Lunar Rover: Advancements in Origami-Inspired Wheels
As South Korea gears up for its lunar exploration mission, slated for 2030, a team of researchers is making strides in developing an avant-garde rover equipped with wheels inspired by origami design principles.
Innovative Design Concepts
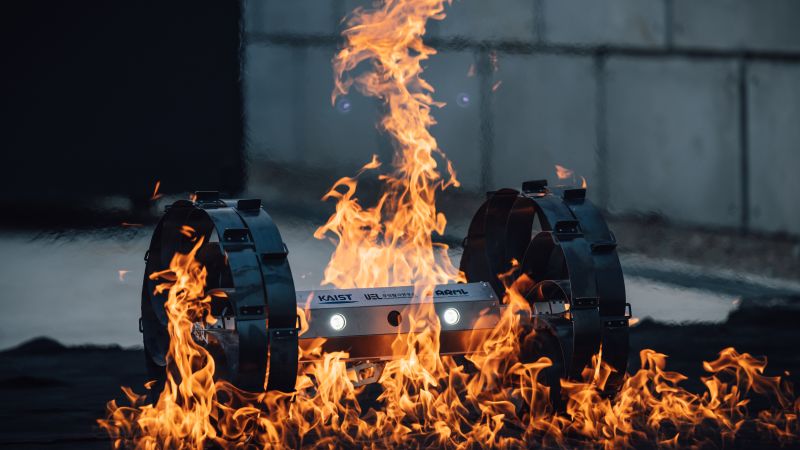
PhD candidate Seong-bin Lee from the Aerospace Robotics and Mechanisms Laboratory (ARML) at the Korea Advanced Institute of Science and Technology (KAIST) shared insights into this cutting-edge development. The wheels consist of flexible metal strips woven together, forming a structure reminiscent of the self-supporting Da Vinci bridge, which utilizes gravity, geometry, and friction for stability.
Characteristics of the Rover’s Wheels
Lee emphasized the “shape-changing ability” of origami as a pivotal feature of their design. The team, alongside the Unmanned Exploration Laboratory (UEL), has spent three years creating a deployable wheel that can shrink to a compact 9 inches in diameter for transport, yet expand to over 20 inches once deployed on the lunar surface.
Dae-Young Lee, ARML director at KAIST, noted that traditional shape-changing mechanisms tend to be bulky and complex, creating challenges for space applications. In contrast, the origami-inspired design simplifies these requirements while enhancing reliability—critical factors for lunar exploration.
Material and Functionality
The wheels are crafted from fire-resistant high-carbon steel, which allows for enhanced flexibility and resilience. This innovative material property is particularly beneficial in navigating the moon’s harsh environmental conditions, including extreme temperature fluctuations exceeding 500°F.
Exploration Goals
The ultimate aim for the rover is to traverse the moon’s lava tubes, remnants of ancient volcanic activity. These underground tunnels may serve as potential habitats for future human colonization, yet their steep terrain poses considerable accessibility challenges.
Testing and Prototyping
The development team has already conducted tests in the natural caves and lava tubes on Jeju Island, South Korea. Additional experiments have focused on how a smaller prototype interacts with various environments, including lunar regolith, challenging temperature conditions, and muddy surfaces.
Next Steps: Autonomous Navigation
Progressing to the next phase, researchers are working towards integrating artificial intelligence into the rover design. Lead master’s student Yiseub Yun is focused on creating AI algorithms that enhance the rover’s adaptability and navigational capabilities. By leveraging reinforcement learning, the rover will be trained through real-world trials, optimizing its structure and wheel configurations for lunar challenges.
South Korea’s Ambitious Space Endeavors
South Korea’s commitment to space exploration is evident in its budget plans, which allocate approximately 1.65 trillion won (around $1.2 billion) for space development by 2027—a 47% increase from the previous year. This initiative is managed by the Korea Aerospace Administration (KASA), established in 2024, with the objective of positioning South Korea among the leading aerospace nations globally.
Inspiration Behind the Innovation
Seong-bin Lee expressed how this project motivates students and engineers alike, emphasizing the spirit of innovation and the desire to tackle challenging paths in science and technology.
As these advancements unfold, the combination of origami-inspired design and autonomous technology positions South Korea’s lunar rover initiative as a noteworthy development in the future of space exploration.
